Work / nissan-humanoid
Nissan Humanoid Capstone
CMU MRSD capstone with industry partner Nissan: teach a Unitree G1 EDU a manufacturing pick-and-place from factory video via VLA / imitation learning.
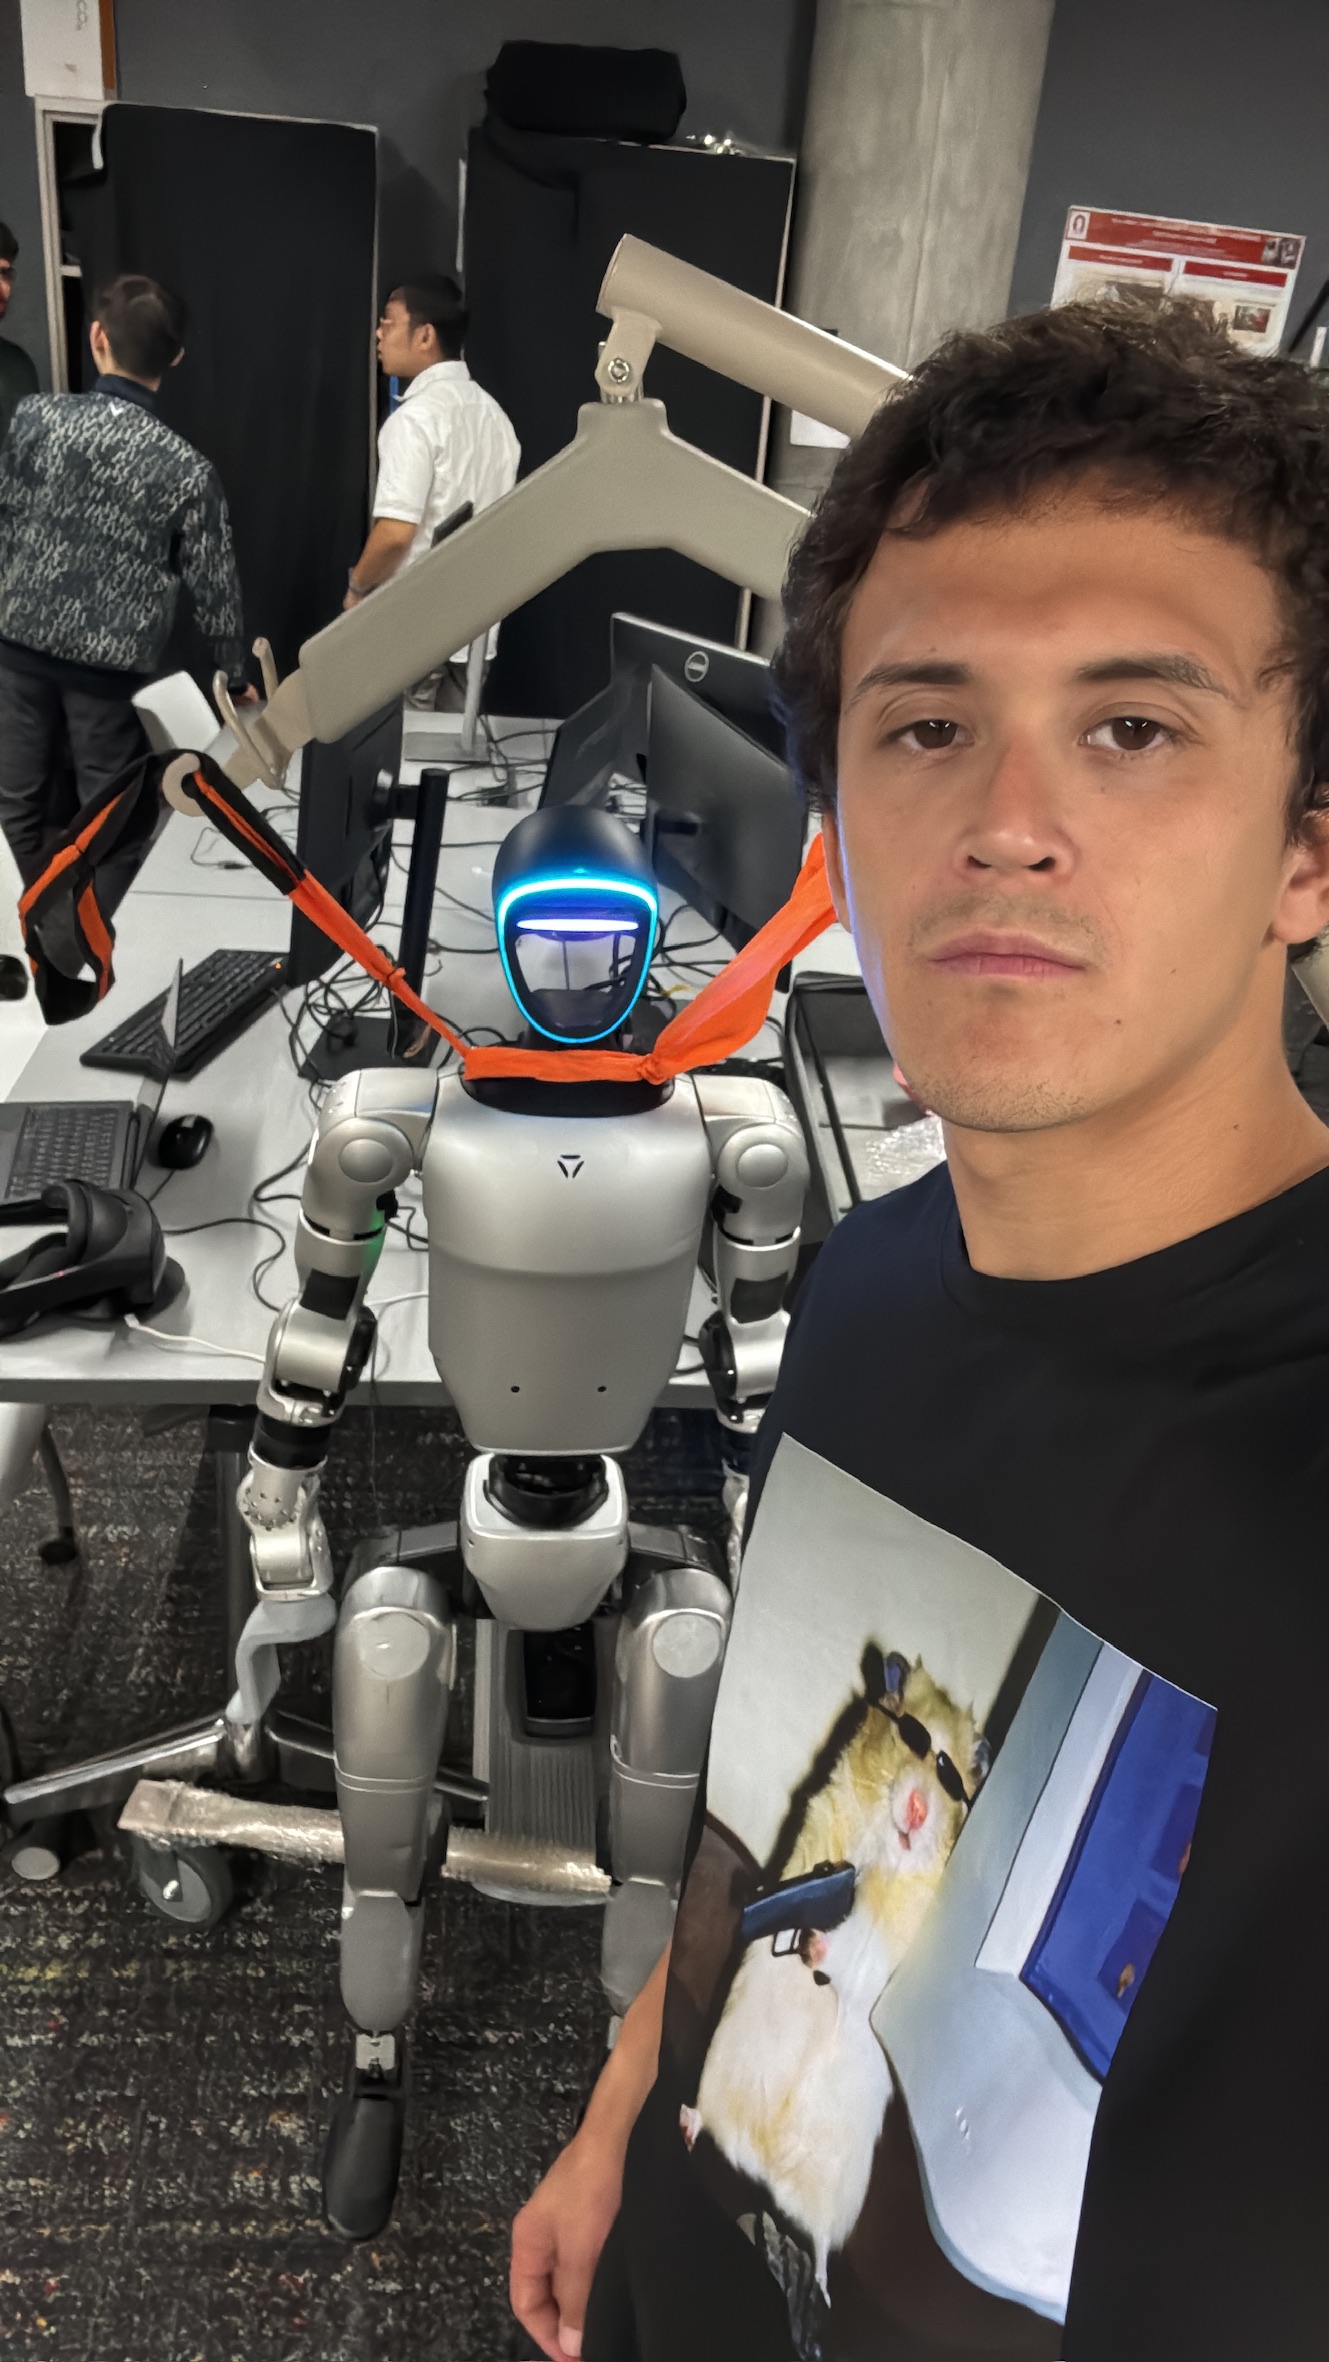
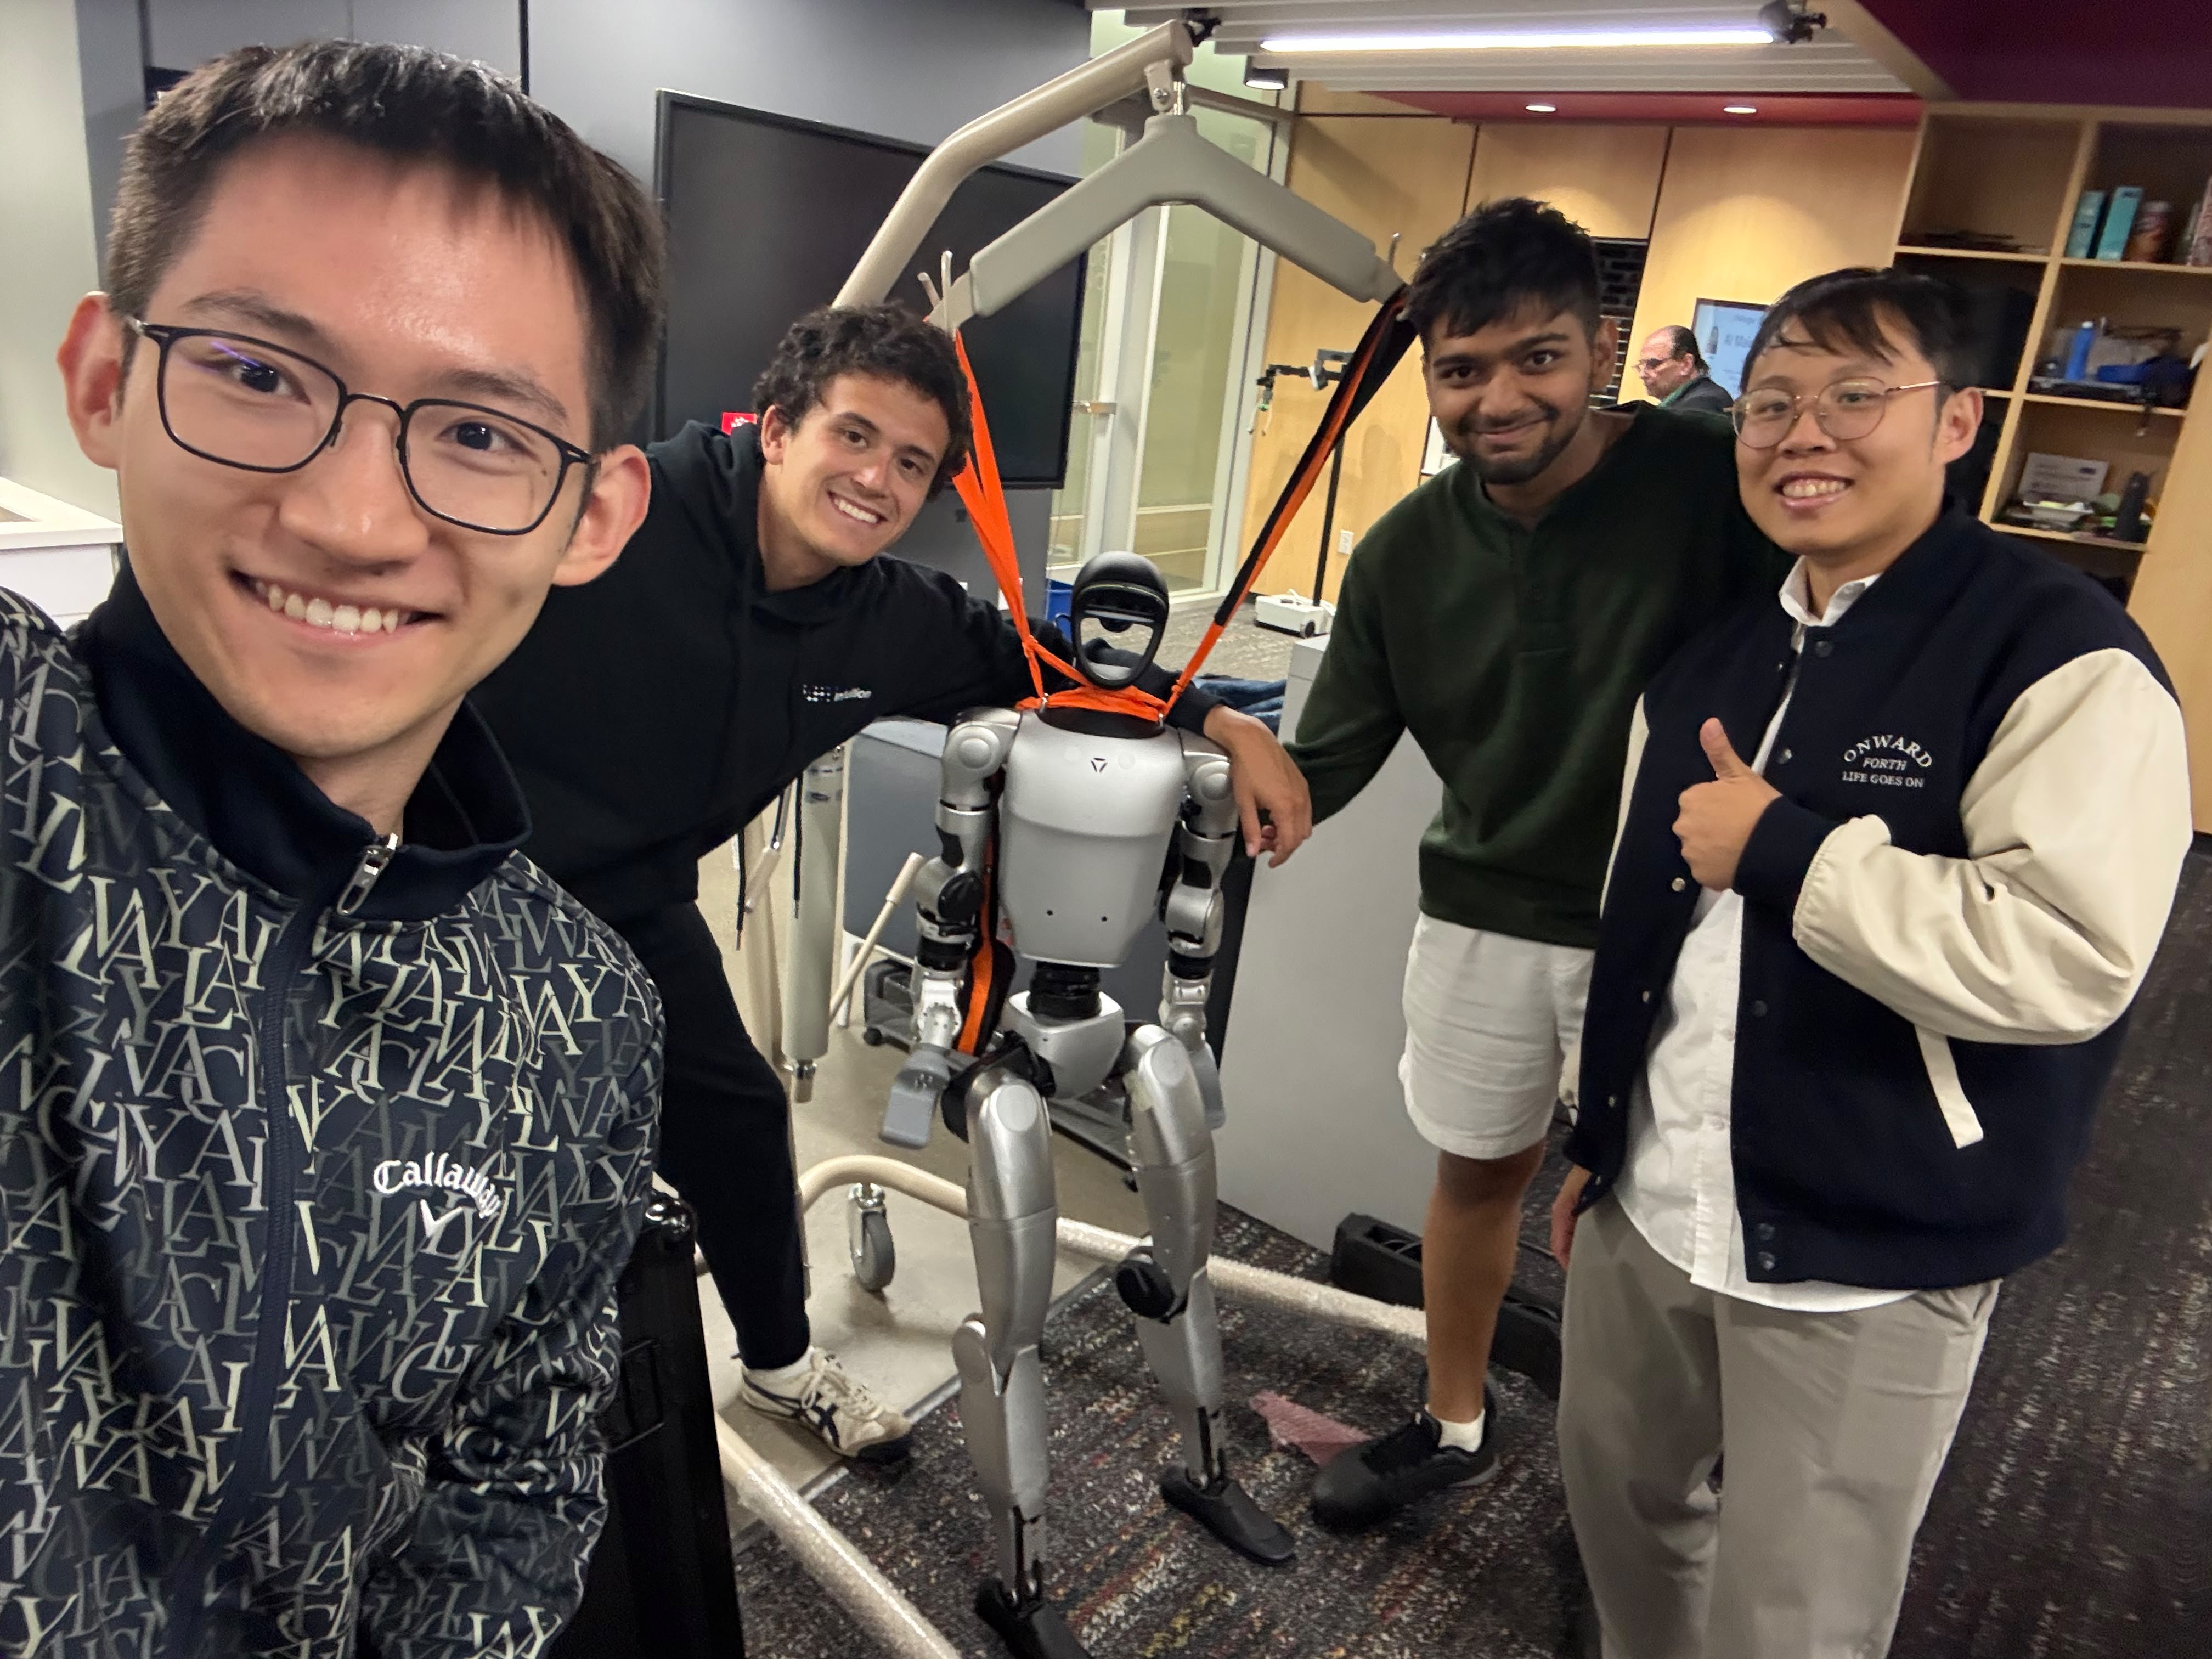
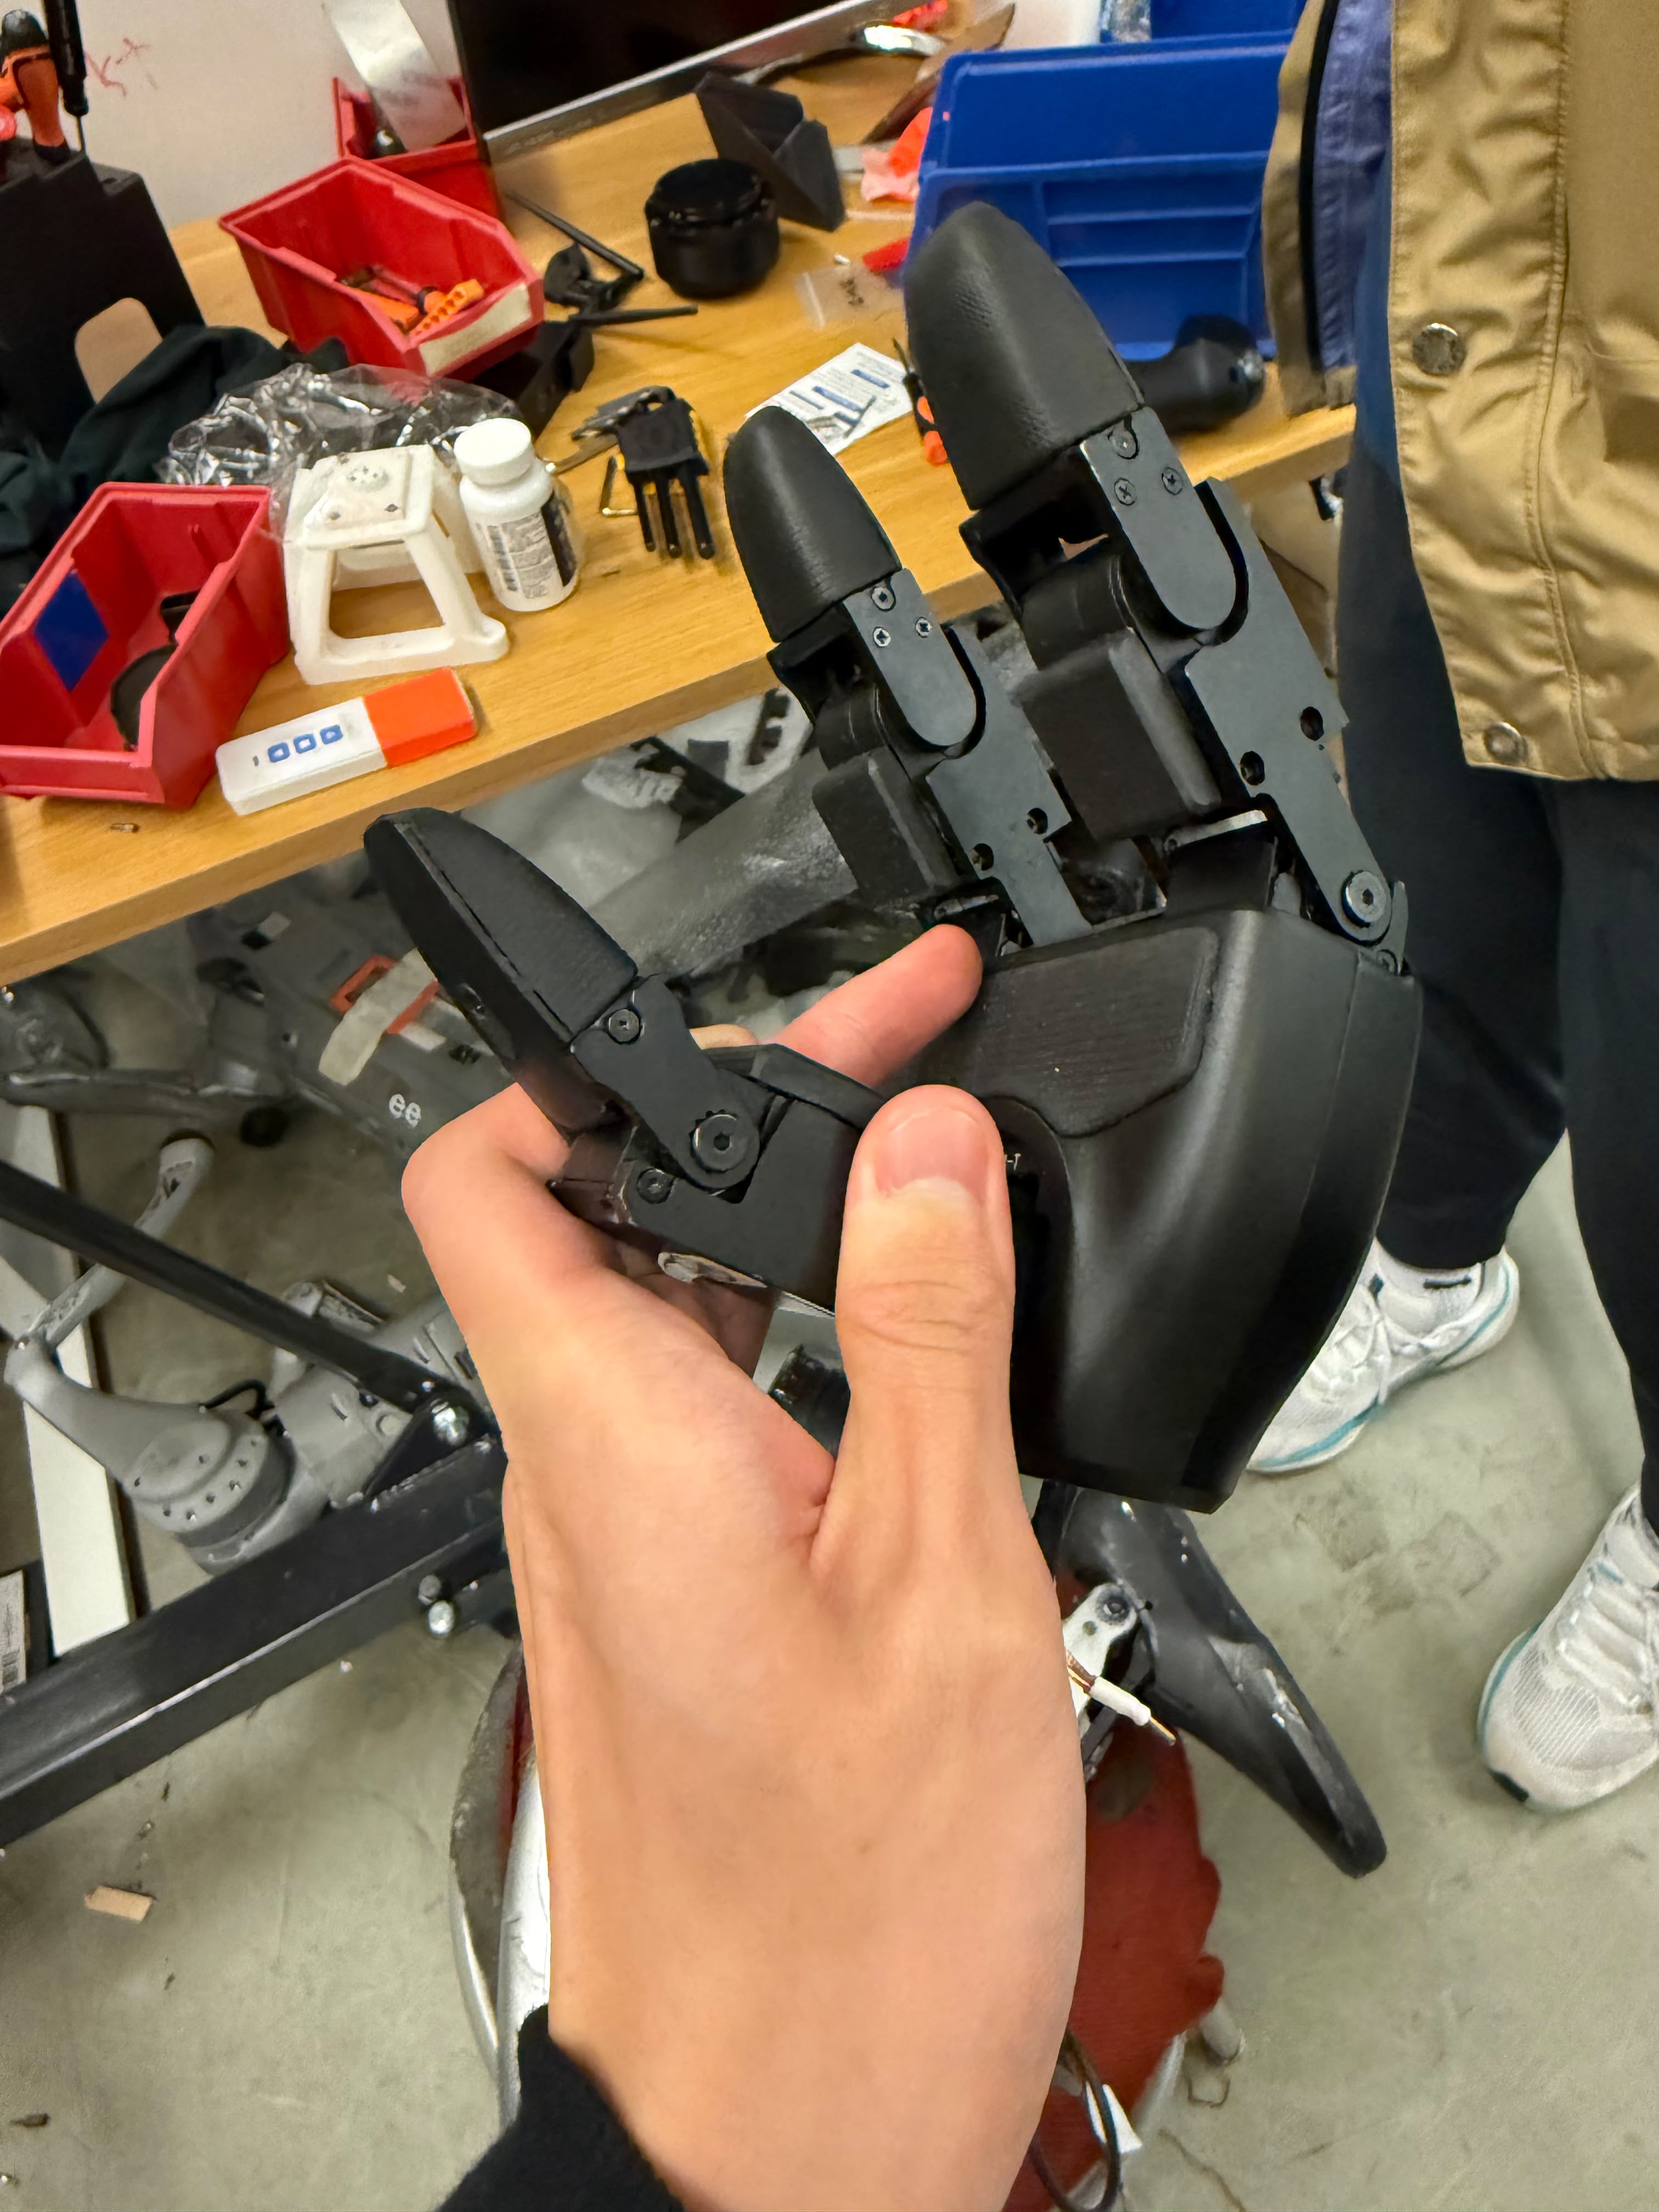
Industry partner: Nissan. These supplied photos show the G1 and team setup; restricted task specifics, sponsor materials, and measured outcomes stay off this page until Nissan clears them.
- Role
- Electrical / embedded lead and project manager
- Timeframe
- CMU MRSD capstone · September 2026 - Present
- Stack
- Unitree G1 EDU, VLA / imitation learning, embedded, video-to-policy, team of five
- Status
- In progress
Problem
Nissan manufacturing pick-and-place (pre-trim interior / air-duct style parts, sub-3 kg) still depends on human operators. The CMU MRSD capstone asks whether a Unitree G1 EDU can learn that class of task primarily from factory video, using vision-language-action (VLA) / imitation learning, instead of writing every motion by hand or relying on teleoperation alone. Exact part geometry and plant footage stay off this page until Nissan clears them.
What I Built
I am electrical and embedded lead, and project manager, on a five-person CMU team (September 2026 - Present). My slice is the robot-side electrical and embedded path that lets a learned policy actually run on the G1 EDU (power, sensing, compute interfaces, bring-up, and integration under the learning stack), plus PM across VLA training, video curation, and real-robot evaluation. The planned comparison is three policies on the real robot: an off-the-shelf baseline, a teleop-only fine-tune, and a video-pretrained policy with light teleop fine-tune. I do not claim the learning research as a solo result, and there are no public metrics yet.
Result
In progress. No public metrics, clips, or stills until Nissan clears them.
Media